From motion.
To real value.
Every production line has its own challenges. Explore S-5 applications and the inputs that shape an effective system.
Robotic welding
Consistent motion for repeated welding paths. Explore the Jasic NB-350E MIG power-source configuration.
Explore applicationHandling & packaging
From pick to place: plan the right end-effector and motion sequence for your product.
Explore applicationProduction integration
Bring the robot, fixtures and manufacturing process together in a system designed around your operation.
Explore application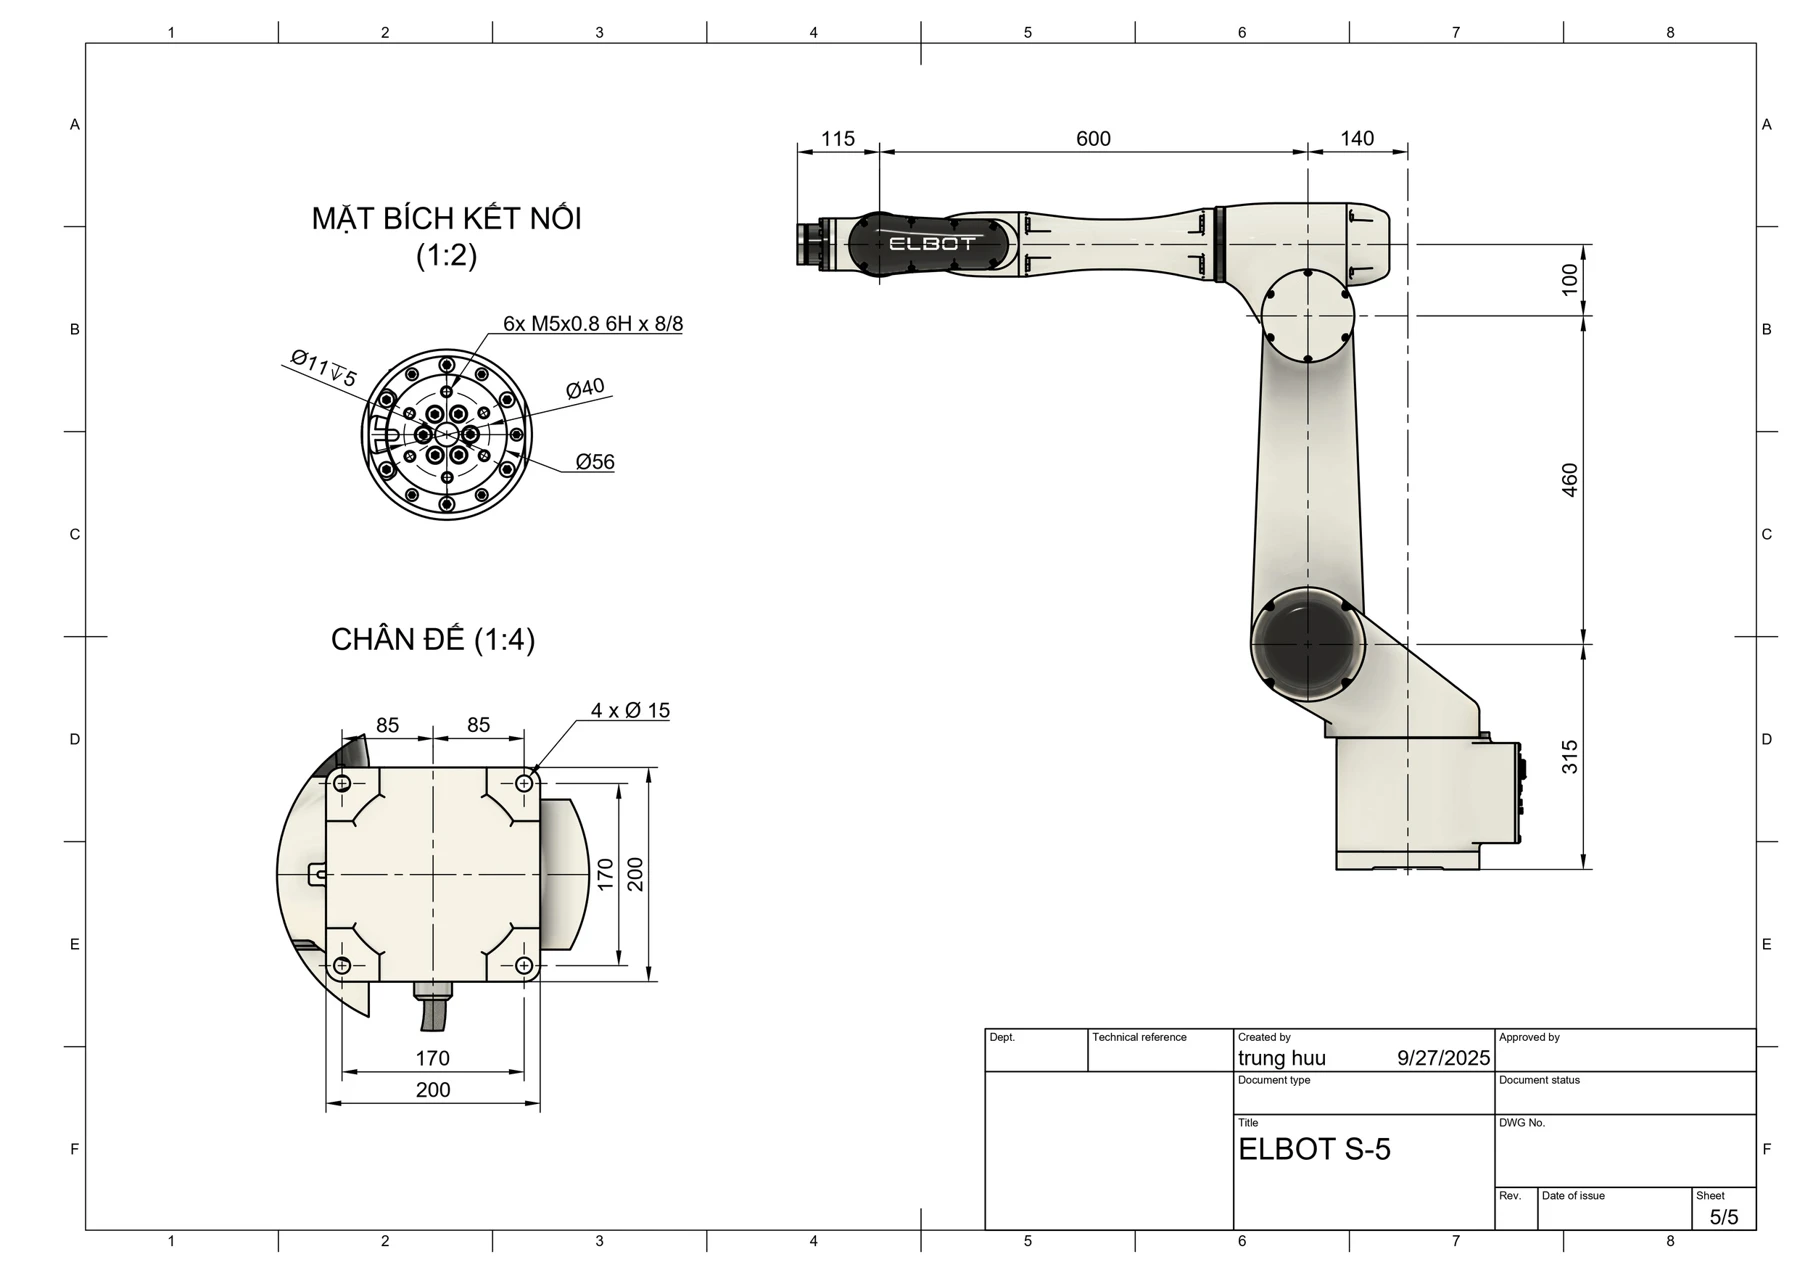 01 / ROBOTIC WELDING
Consistency in
every welding path.
The six-axis structure enables multiple torch approaches. The brochure pairs the robot with a Jasic NB-350E source, featuring 50–350 A MIG current and 0.8–1.2 mm wire.
What to prepare
- Material, thickness and part drawings
- Welding paths, fixtures and quality requirements
- Target cycle time and welding-area safeguards
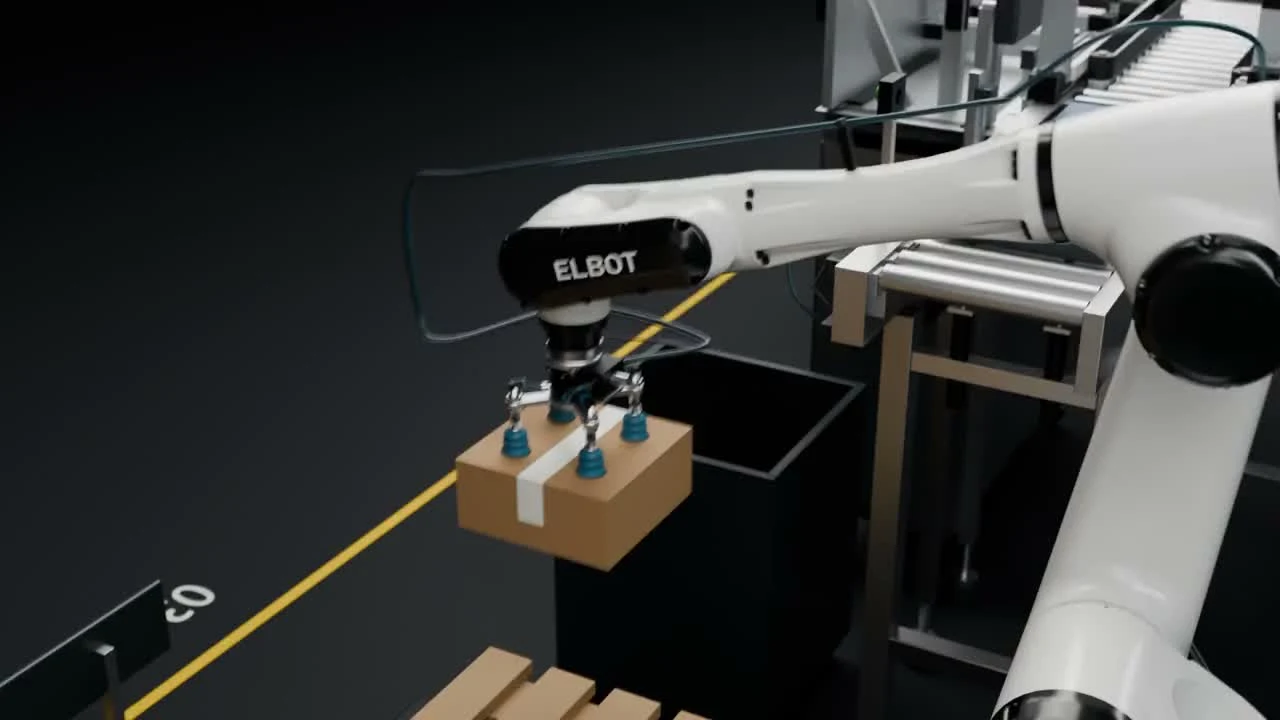 3D handling application simulation
The right placement.
A connected process.
A 1,315 mm reach and up to 10 kg payload provide a basis for evaluating part transfer, product handling and packaging. End-effectors, fixtures and conveyor coordination are selected around the actual workpiece.
- Account for both gripper and product weight
- Define pick points, placement and collision-free space
- Validate handling stability with actual product samples
One robot.
Part of a bigger system.
Performance comes from the way the components work together. Start with the line layout, control interfaces, operating requirements and acceptance criteria to define the integration scope.
- Review workspace and robot mounting position
- Assess interfaces with existing equipment
- Define safeguarding, operation and maintenance
See the possibilities.
Imagine your production line.
Explore a simulated automation workflow combining Elbot and Delta X.
Your next challenge.
Our next move.
Tell us about your process. Let’s find the right robot configuration.